
Custom robot tooling
A gripper concept built around the workpiece, robot interface and cycle requirements. Lightweight and rigid components can use different manufacturing processes within the same assembly.
Project references
Short project descriptions explaining the task, the chosen manufacturing route and how the solution fits into the overall process.
A gripper concept built around the workpiece, robot interface and cycle requirements. Lightweight and rigid components can use different manufacturing processes within the same assembly.

The same geometry produced in multiple color variants with repeatable settings and consistent appearance.

A load-bearing printed part for a prototype or fixture, with geometry that can be iterated quickly between revisions.
Rigid, precise interfaces made from a CAD model or technical drawing, either as standalone parts or within an EOAT system.
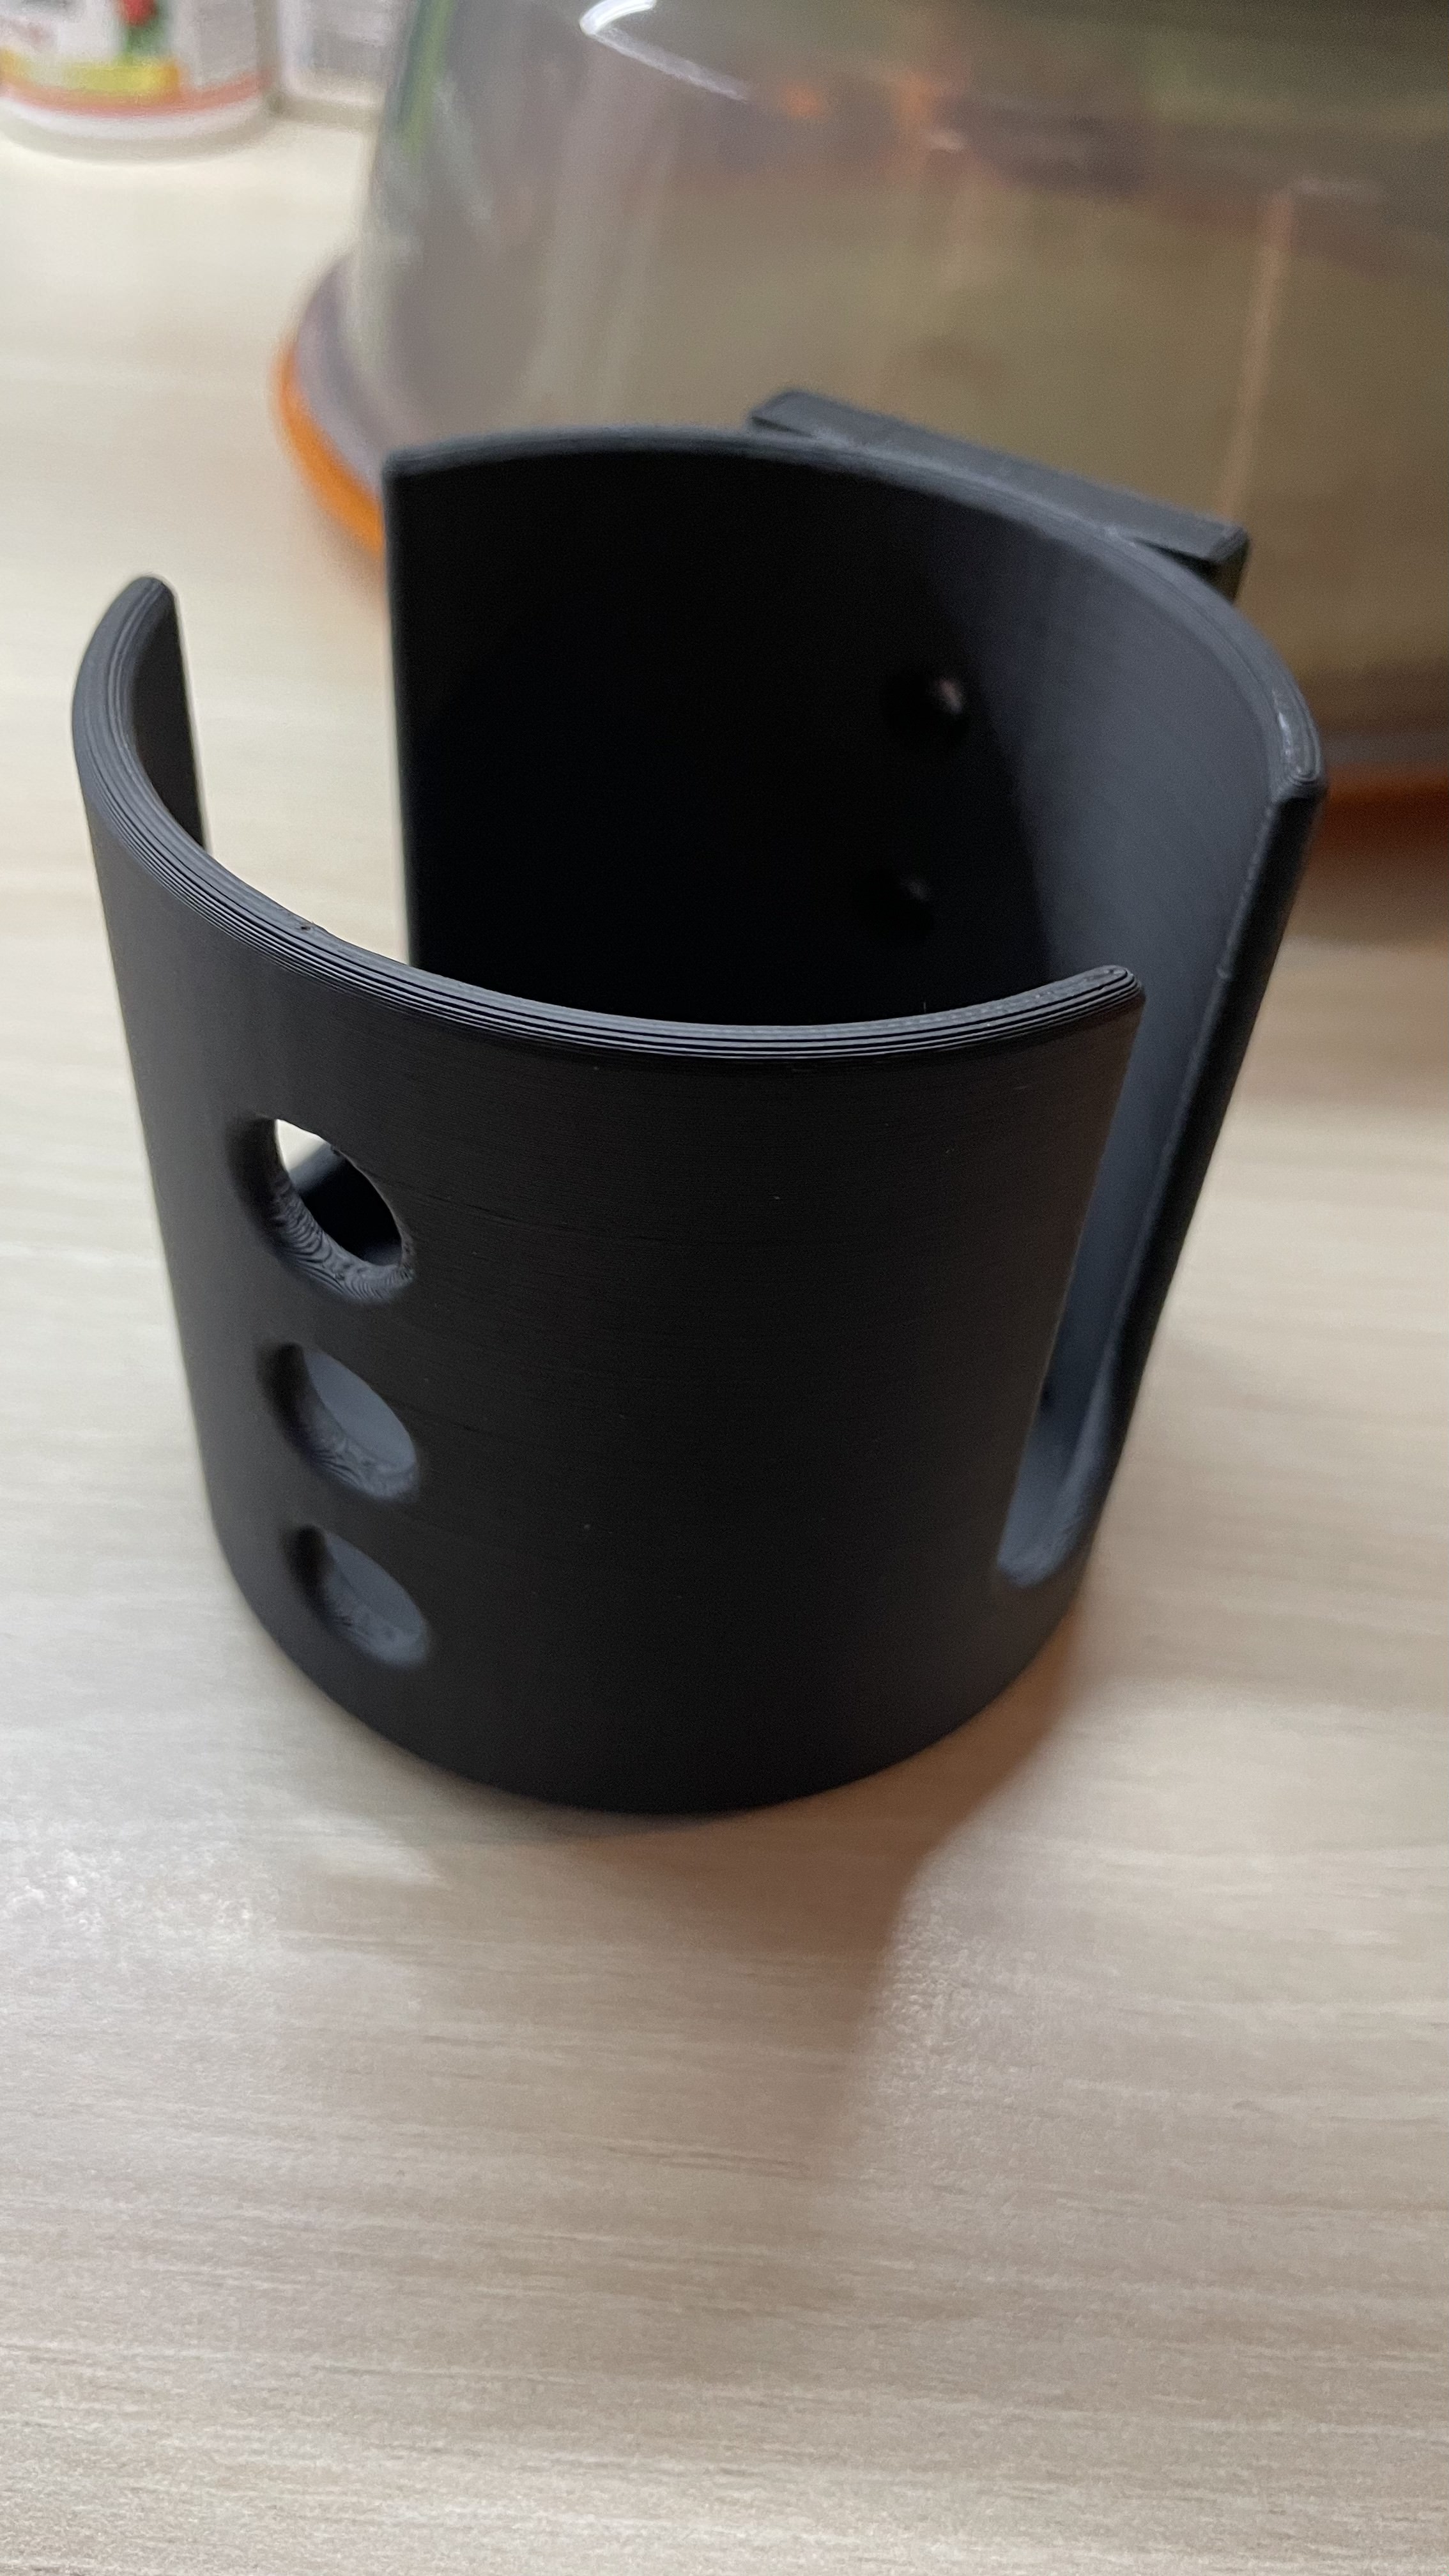
A low-volume custom component where fast production and geometric freedom matter more than tooling cost.

Fast physical prototype for form, fit and ergonomic checks before a final manufacturing decision.